Computer vision
Vision Inspection Pipeline
Concept system — a computer-vision inspection pipeline: acquisition, preprocessing, detection, classification, confidence gating and human review, with auditable reports.
- Evidence
- Concept system
- Category
- Computer vision
Overview
A design for automated visual inspection that knows when it is unsure: detection and classification models behind a calibrated confidence gate, with human review for everything below it.
Problem
Visual inspection is repetitive and inconsistent between people, but a model that is silently wrong is worse than a slow human. The pipeline has to detect defects, know when it is unsure, and leave an auditable record of every decision.
Architecture
Image acquisition feeds a preprocessing stage (normalisation, alignment); a detector proposes regions, a classifier labels them, and a confidence gate routes low-confidence items to a human reviewer whose decisions are stored as new labelled data. Results, images and model versions are written to an inspection report store.
Intelligence layer
A detection model for localisation and a classifier for defect type, each versioned; calibration of confidence thresholds on held-out data decides what the system may accept without review.
Design objective
Design objective: no automated accept below a calibrated confidence threshold, every decision traceable to an image and a model version, and reviewer corrections feeding the next training set.
Related projects
Artificial intelligence
Trading AI Assistance — Backend Architecture
The backend architecture of a trading-analysis platform: market-data ingestion, strategy execution, explainable AI signals, a model registry and leakage-safe backtesting, as a modular monolith with a Python inference service.
Stack
Artificial intelligence
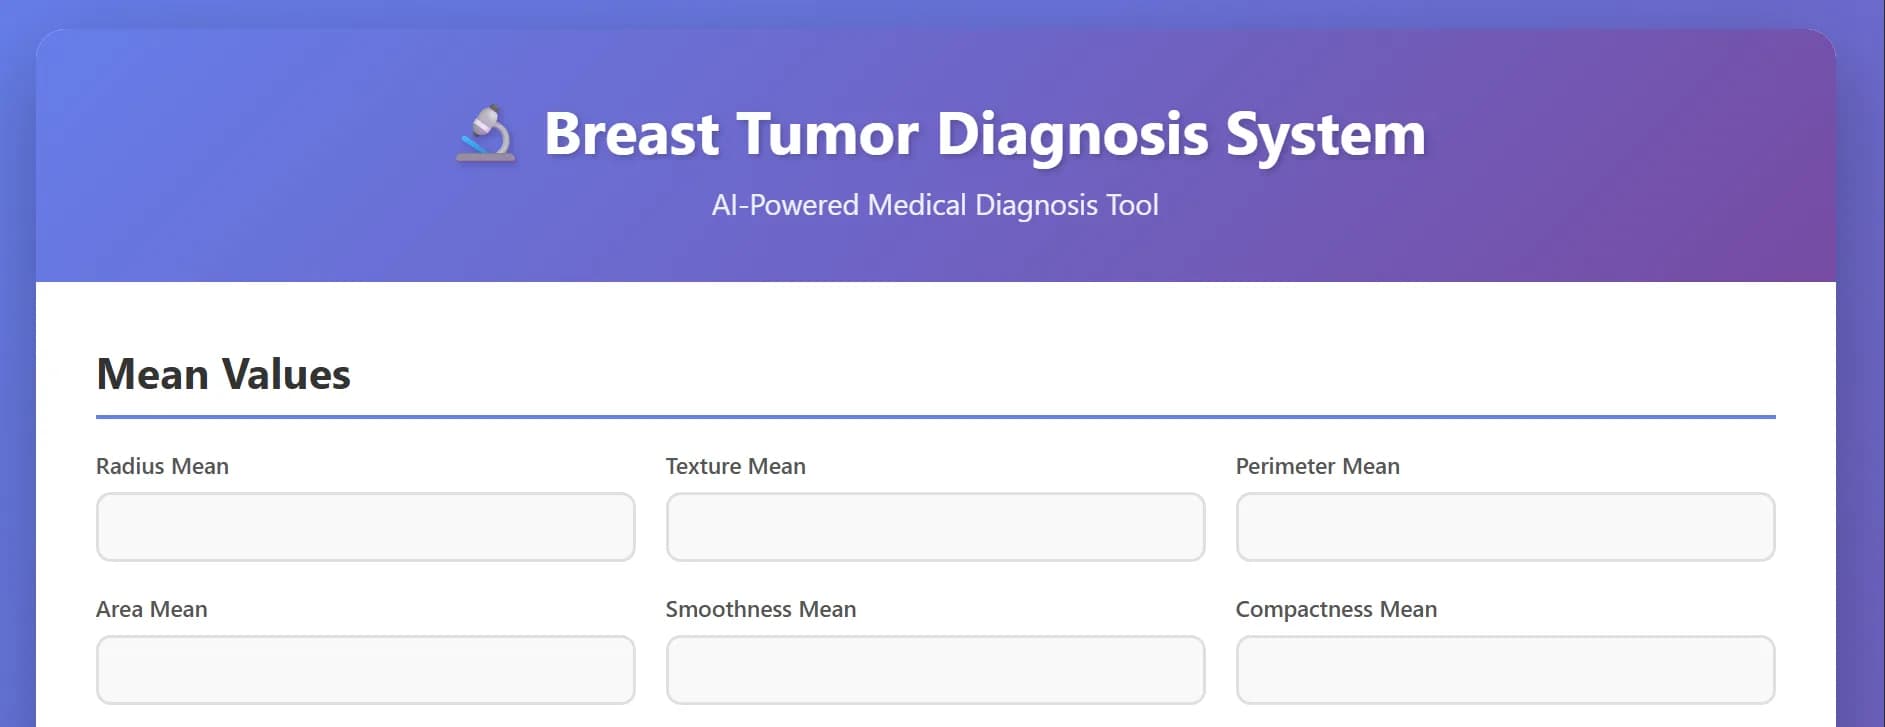
Breast Tumor Diagnosis System
A K-nearest-neighbours classifier that labels a breast tumour benign or malignant from 30 diagnostic features, served through a Flask REST API with a web interface.
Stack
Robotics
Robot Obstacles Avoidance System (Fuzzy System, Neural Networks)
Obstacle-aware robot navigation control: a 15-rule fuzzy inference system and a custom ANFIS that map obstacle distance and target angle to speed and turn.
Stack